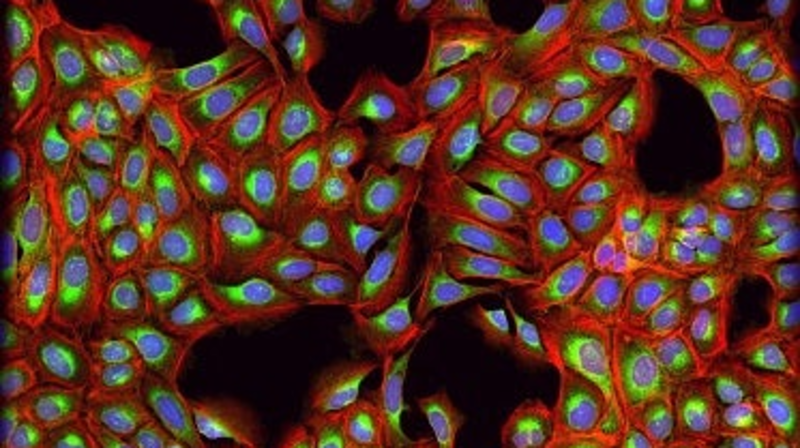
@article{seal2026counting,title={Counting cells can accurately predict small-molecule bioactivity benchmarks},author={Seal, Srijit and Dee, William and Shah, Adit and Cerisier, Natacha and Zhang, Andrew and Miglietta, Esteban and Titterton, Katherine and Cabrera, {\'A}ngel Alexander and Boiko, Daniil and Beatson, Alex and Slabaugh, Gregory and Taboureau, Olivier and Carreras Puigvert, Jordi and Singh, Shantanu and Spjuth, Ola and Bender, Andreas and Carpenter, Anne E.},journal={Nature Communications},year={2026},doi={10.1038/s41467-026-68725-5}}
2025
Nature Neuroscience
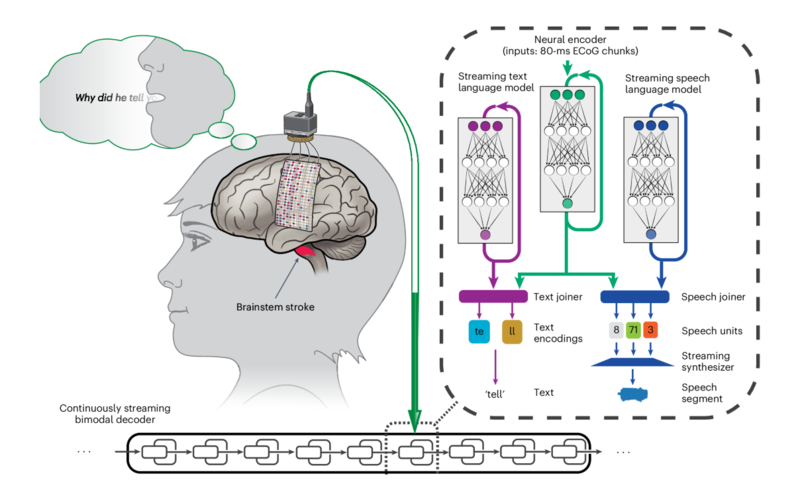
A streaming brain-to-voice neuroprosthesis to restore naturalistic communication
Kaylo T. Littlejohn, 9 more authors, Adit Shah, 5 more authors
@article{littlejohn2025streaming,title={A streaming brain-to-voice neuroprosthesis to restore naturalistic communication},author={Littlejohn, Kaylo T. and Cho, Cheol Jun and Liu, Jessie R. and Silva, Alexander B. and Yu, Bohan and Anderson, Vanessa R. and Kurtz-Miott, Cady M. and Brosler, Samantha and Kashyap, Anshul P. and Hallinan, Irina P. and Shah, Adit and Tu-Chan, Adelyn and Ganguly, Karunesh and Moses, David A. and Chang, Edward F. and Anumanchipalli, Gopala K.},journal={Nature Neuroscience},volume={28},pages={902--912},year={2025},doi={10.1038/s41593-025-01905-6}}
IEEE CSM
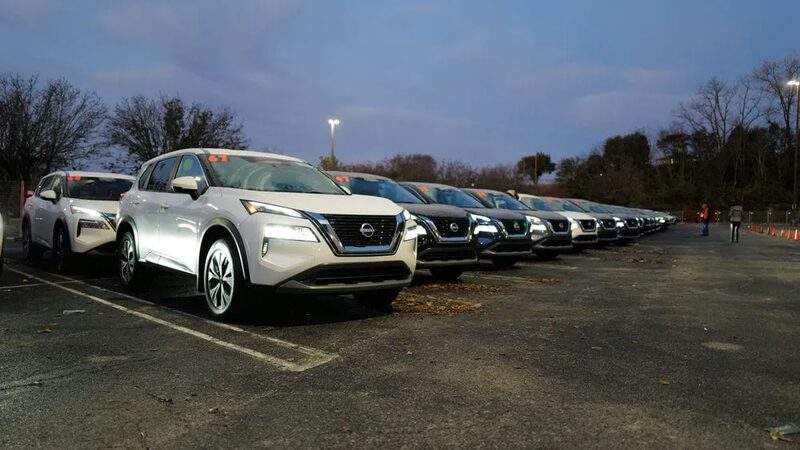
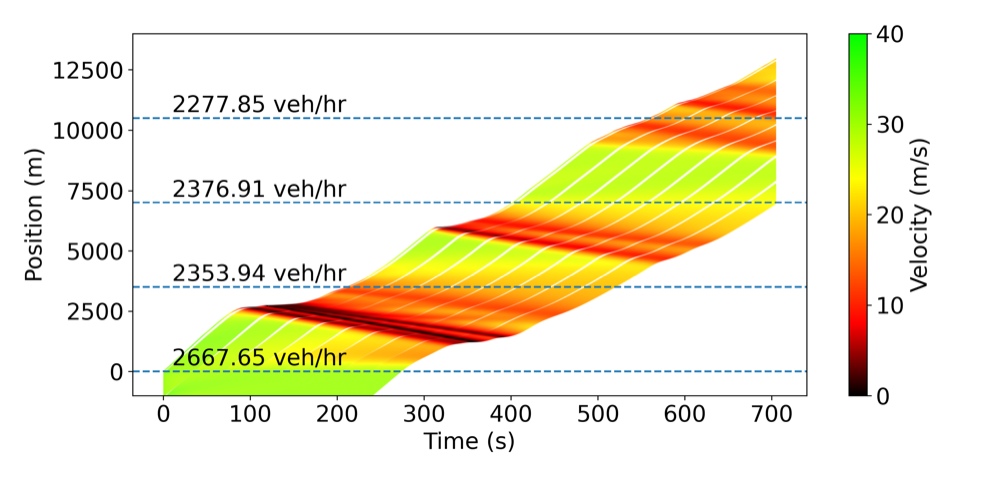
Traffic control via connected and automated vehicles (CAVs): An open-road field experiment with 100 CAVs
Jonathan W. Lee1, 14 more authors, Adit Shah2, 48 more authors
@article{lee2025traffic,title={Traffic control via connected and automated vehicles ({CAVs}): An open-road field experiment with 100 {CAVs}},author={Lee1, Jonathan W. and Wang1, Han and Jang1, Kathy and Lichtl{\'e}1, Nathan and Hayat1, Amaury and Bunting1, Matthew and Alanqary2, Arwa and Barbour2, William and Fu2, Zhe and Gong2, Xiaoqian and Gunter2, George and Hornstein2, Sharon and Kreidieh2, Abdul Rahman and Nice2, Matthew W. and Richardson2, William A. and Shah2, Adit and Vinitsky2, Eugene and Wu2, Fangyu and Xiang2, Shengquan and Almatrudi3, Sulaiman and Althukair3, Fahd and Bhadani3, Rahul and Carpio3, Joy and Chekroun3, Raphael and Cheng3, Eric and Chiri3, Maria Teresa and Chou3, Fang-Chieh and Delorenzo3, Ryan and Gibson3, Marsalis and Gloudemans3, Derek and Gollakota3, Anish and Ji3, Junyi and Keimer3, Alexander and Khoudari3, Nour and Mahmood3, Malaika and Mahmood3, Mikail and Matin3, Hossein Nick Zinat and McQuade3, Sean and Ramadan3, Rabie and Urieli3, Daniel and Wang3, Xia and Wang3, Yanbing and Xu3, Rita and Yao3, Mengsha and You3, Yiling and Zach{\'a}r3, Gergely and Zhao3, Yibo and Ameli4, Mostafa and Baig4, Mirza Najamuddin and Bhaskaran4, Sarah and Butts4, Kenneth and Gowda4, Manasi and Janssen4, Caroline and Lee4, John and Pedersen4, Liam and Wagner4, Riley and Zhang4, Zimo and Zhou4, Chang and Work, Daniel B. and Seibold, Benjamin and Sprinkle, Jonathan and Piccoli, Benedetto and Delle Monache, Maria Laura and Bayen, Alexandre M.},journal={IEEE Control Systems},volume={45},number={1},pages={28--60},year={2025},doi={10.1109/MCS.2024.3498552}}
IEEE CSM
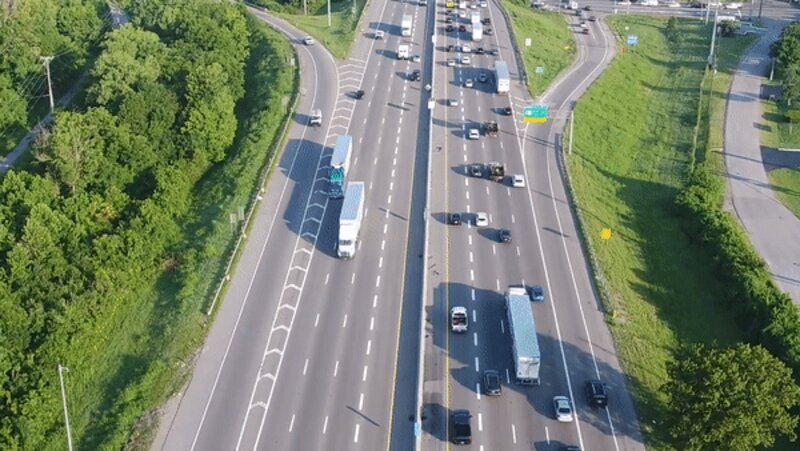
Reinforcement learning-based oscillation dampening: Scaling up single-agent reinforcement learning algorithms to a 100-autonomous-vehicle highway field operational test
@article{jang2025oscillation,title={Reinforcement learning-based oscillation dampening: Scaling up single-agent reinforcement learning algorithms to a 100-autonomous-vehicle highway field operational test},author={Jang, Kathy and Lichtl{\'e}, Nathan and Vinitsky, Eugene and Shah, Adit and Bunting, Matthew and Nice, Matthew and Piccoli, Benedetto and Seibold, Benjamin and Work, Daniel B. and Delle Monache, Maria Laura and Sprinkle, Jonathan and Lee, Jonathan W. and Bayen, Alexandre M.},journal={IEEE Control Systems},volume={45},number={1},pages={61--94},year={2025},doi={10.1109/MCS.2024.3503372}}
2023
IEEE ITSC
Traffic smoothing controllers for autonomous vehicles using deep reinforcement learning and real-world trajectory data
Nathan Lichtlé*, Kathy Jang*, Adit Shah*, 3 more authors
IEEE International Conference on Intelligent Transportation Systems (ITSC), 2023
@inproceedings{lichtle2023traffic,title={Traffic smoothing controllers for autonomous vehicles using deep reinforcement learning and real-world trajectory data},author={Lichtl{\'e}, Nathan and Jang, Kathy and Shah, Adit and Vinitsky, Eugene and Lee, Jonathan W. and Bayen, Alexandre M.},booktitle={IEEE International Conference on Intelligent Transportation Systems (ITSC)},pages={4346--4351},year={2023},doi={10.1109/ITSC57777.2023.10421828},}